RoboticsAdvanced
WildeBeest Pro
A complete dual-ROS autonomous-robot reference stack joining CAD, simulation, navigation, sensor fusion, a safety-oriented Arduino controller and an operator dashboard.
ROS 2 JazzyPythonC++Arduino

Explore migrated Academy4Tech prototypes and open-source systems. Missing facts stay marked as missing; repositories remain the technical source of truth.
A complete dual-ROS autonomous-robot reference stack joining CAD, simulation, navigation, sensor fusion, a safety-oriented Arduino controller and an operator dashboard.
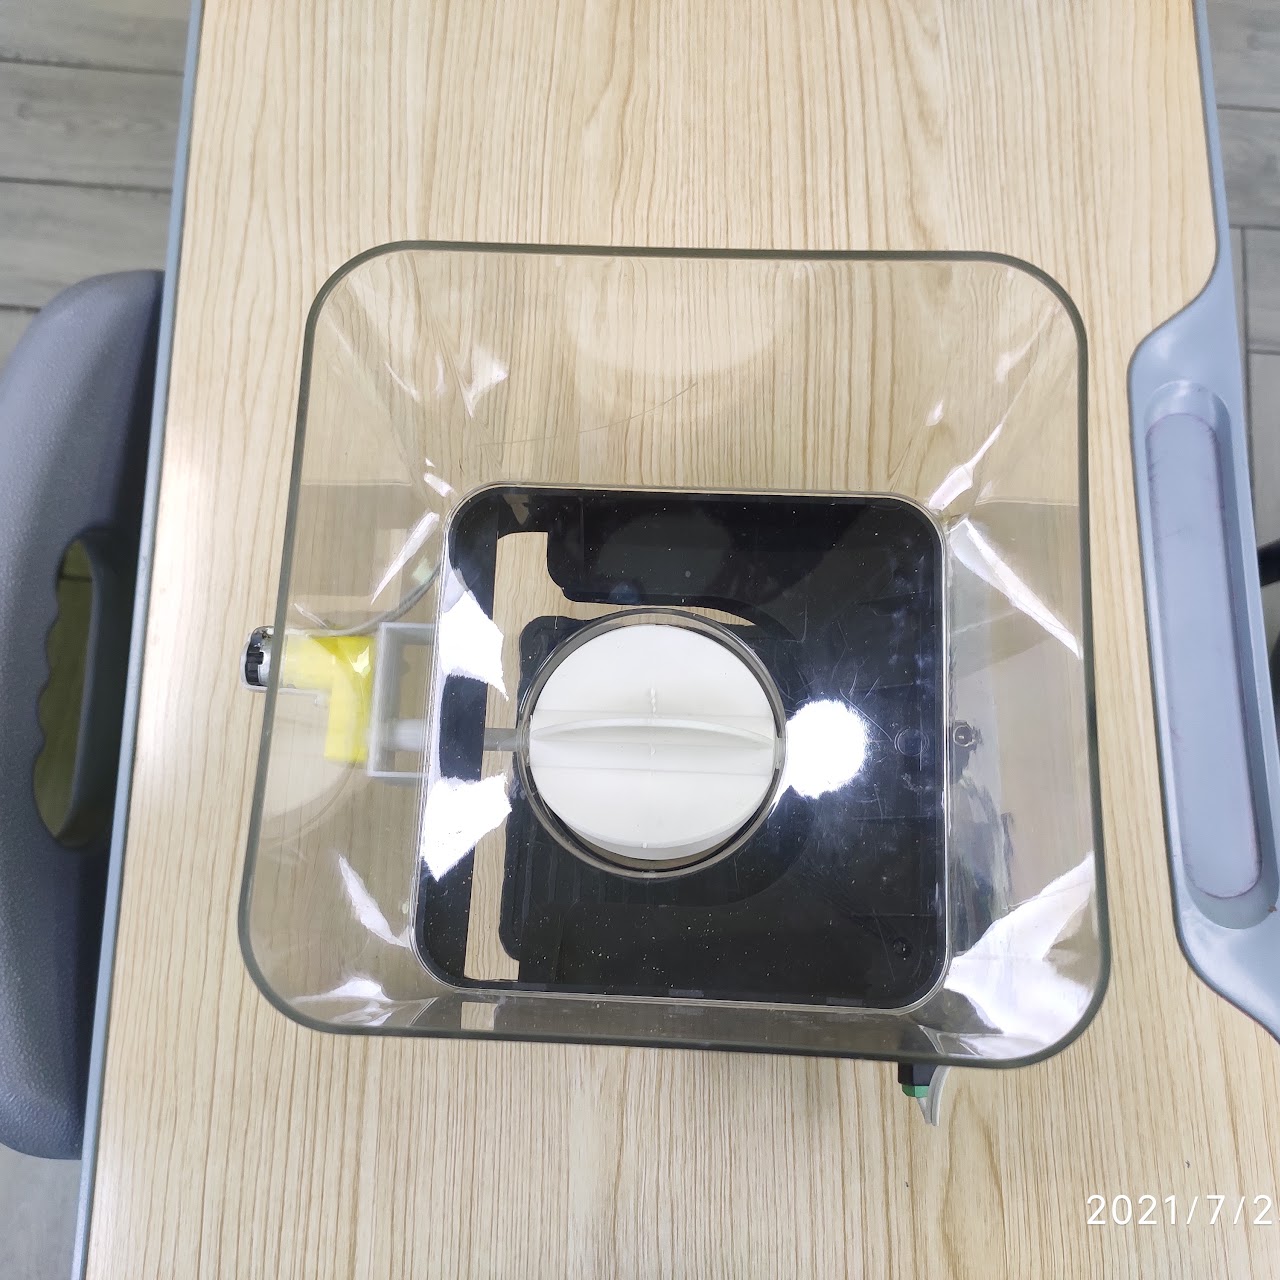
An Arduino-based timed feeder concept with three configurable feeding times, an LCD and keypad input.
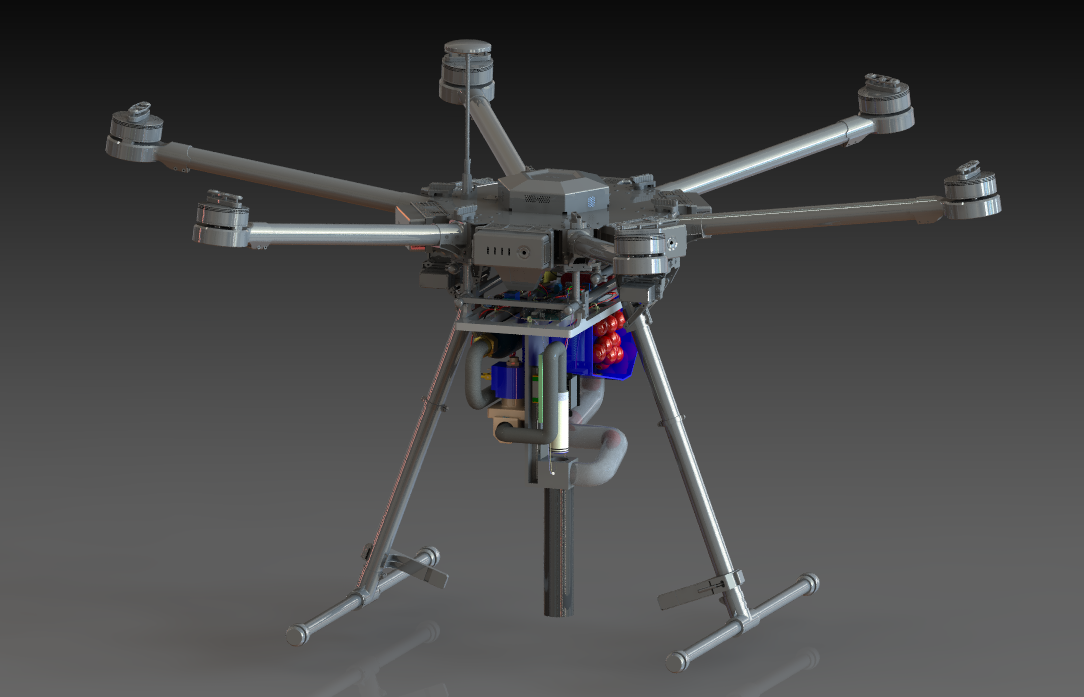
A concept and prototype for a DJI M600 Pro planting payload using a 3D-printed seed container and pneumatic firing mechanism.
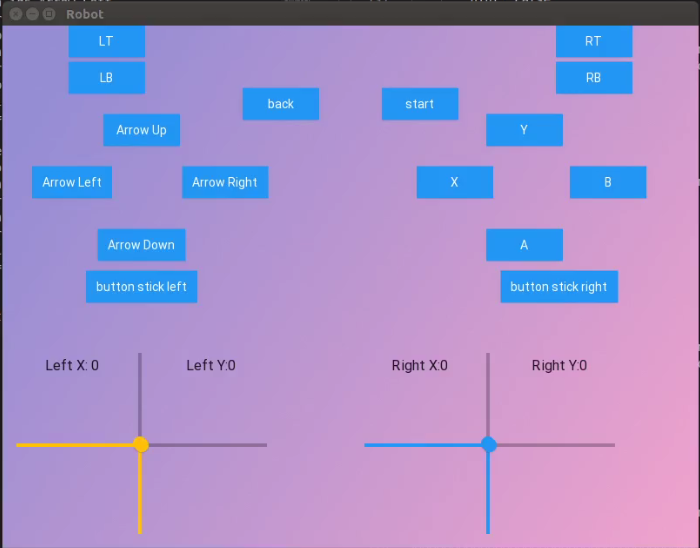
A Python and KivyMD interface that visualizes Logitech F710 joystick data carried through ROS.
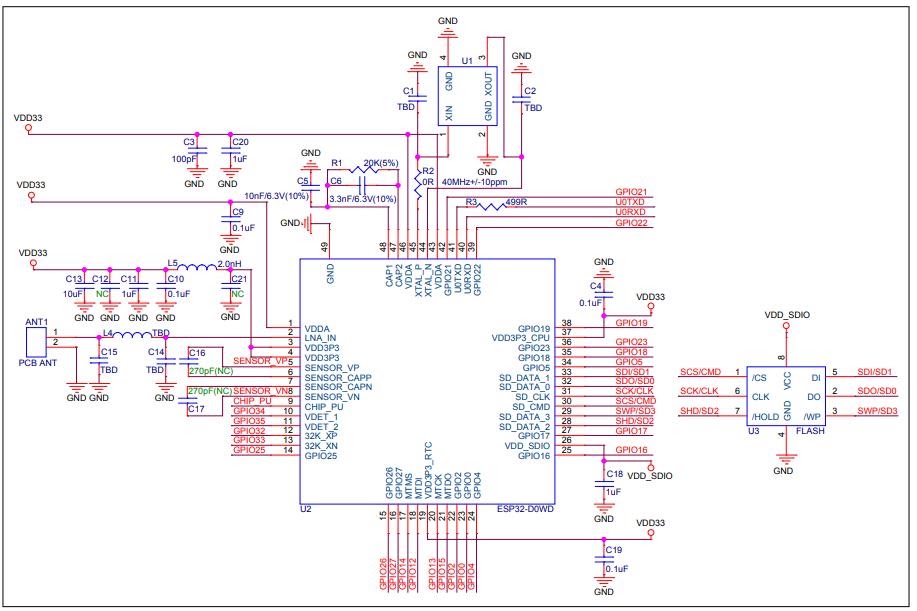
Design notes for an ESP32 board with Wi-Fi, Bluetooth and CH340-based USB programming.
No projects match those filters.